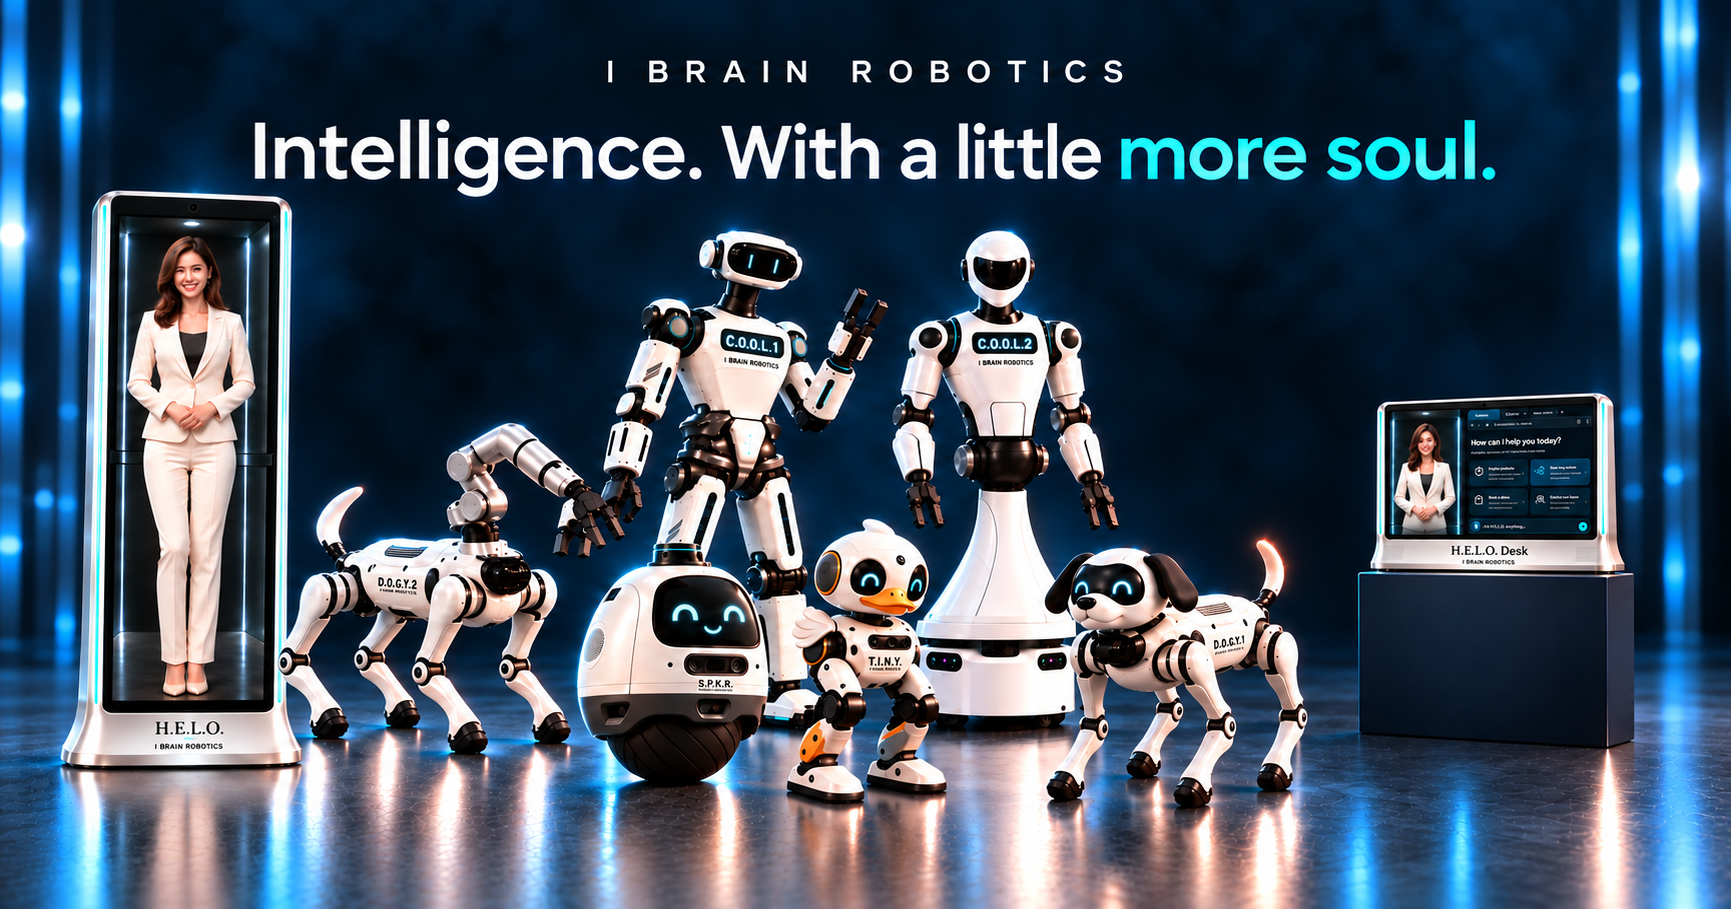
More natural, by design
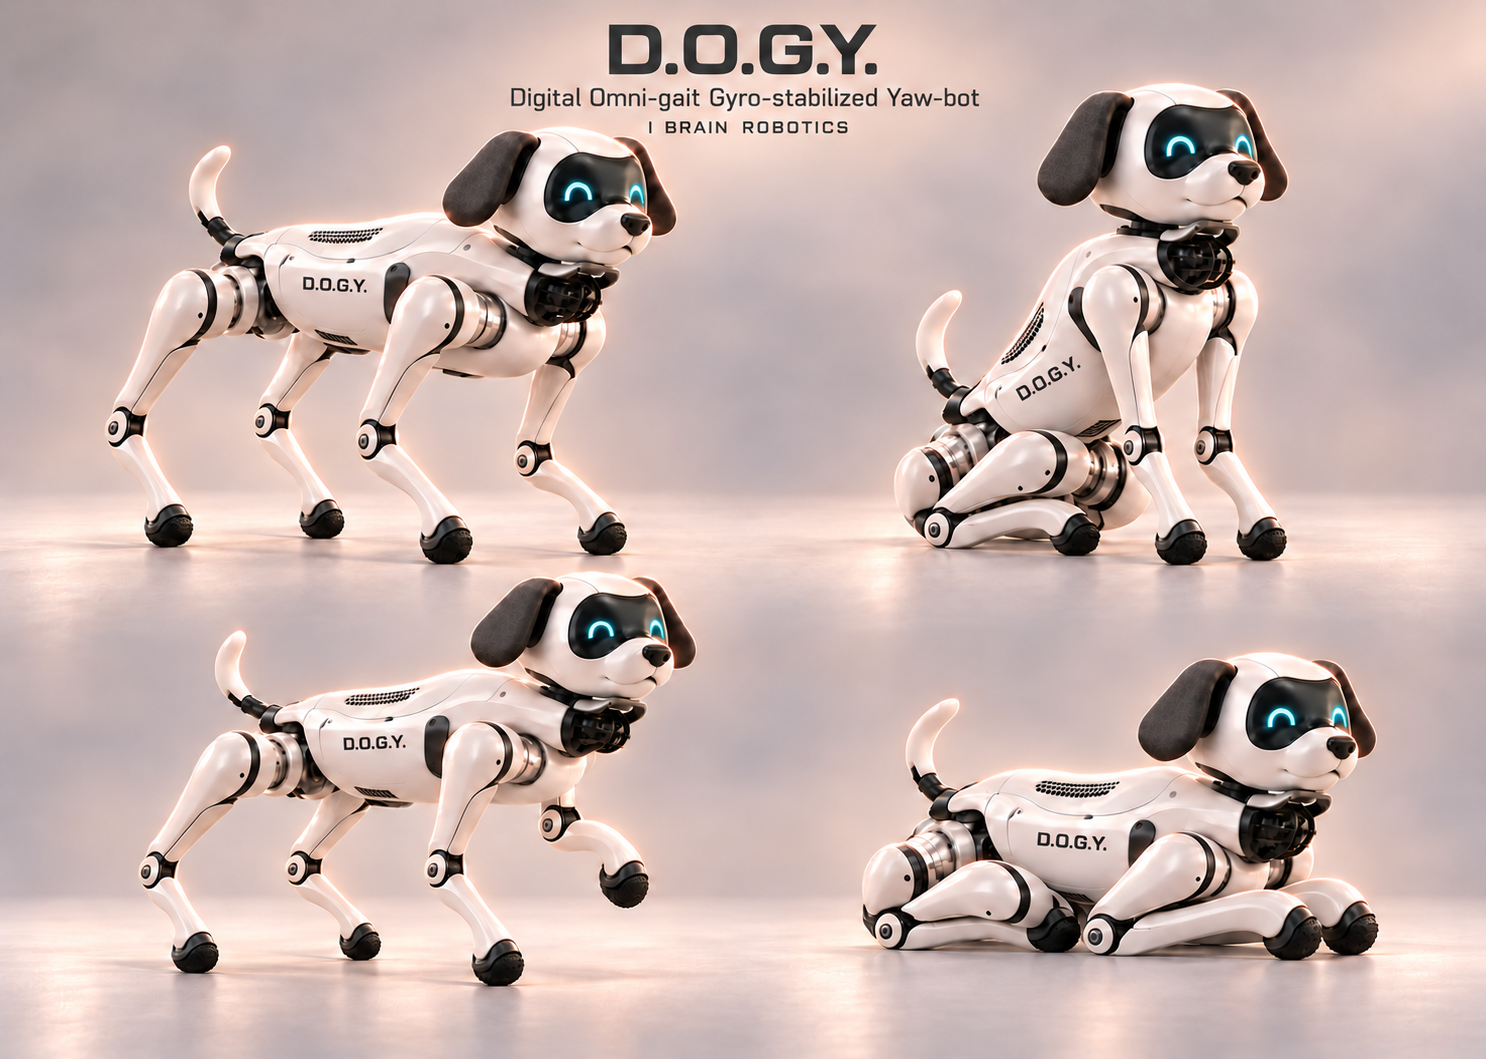
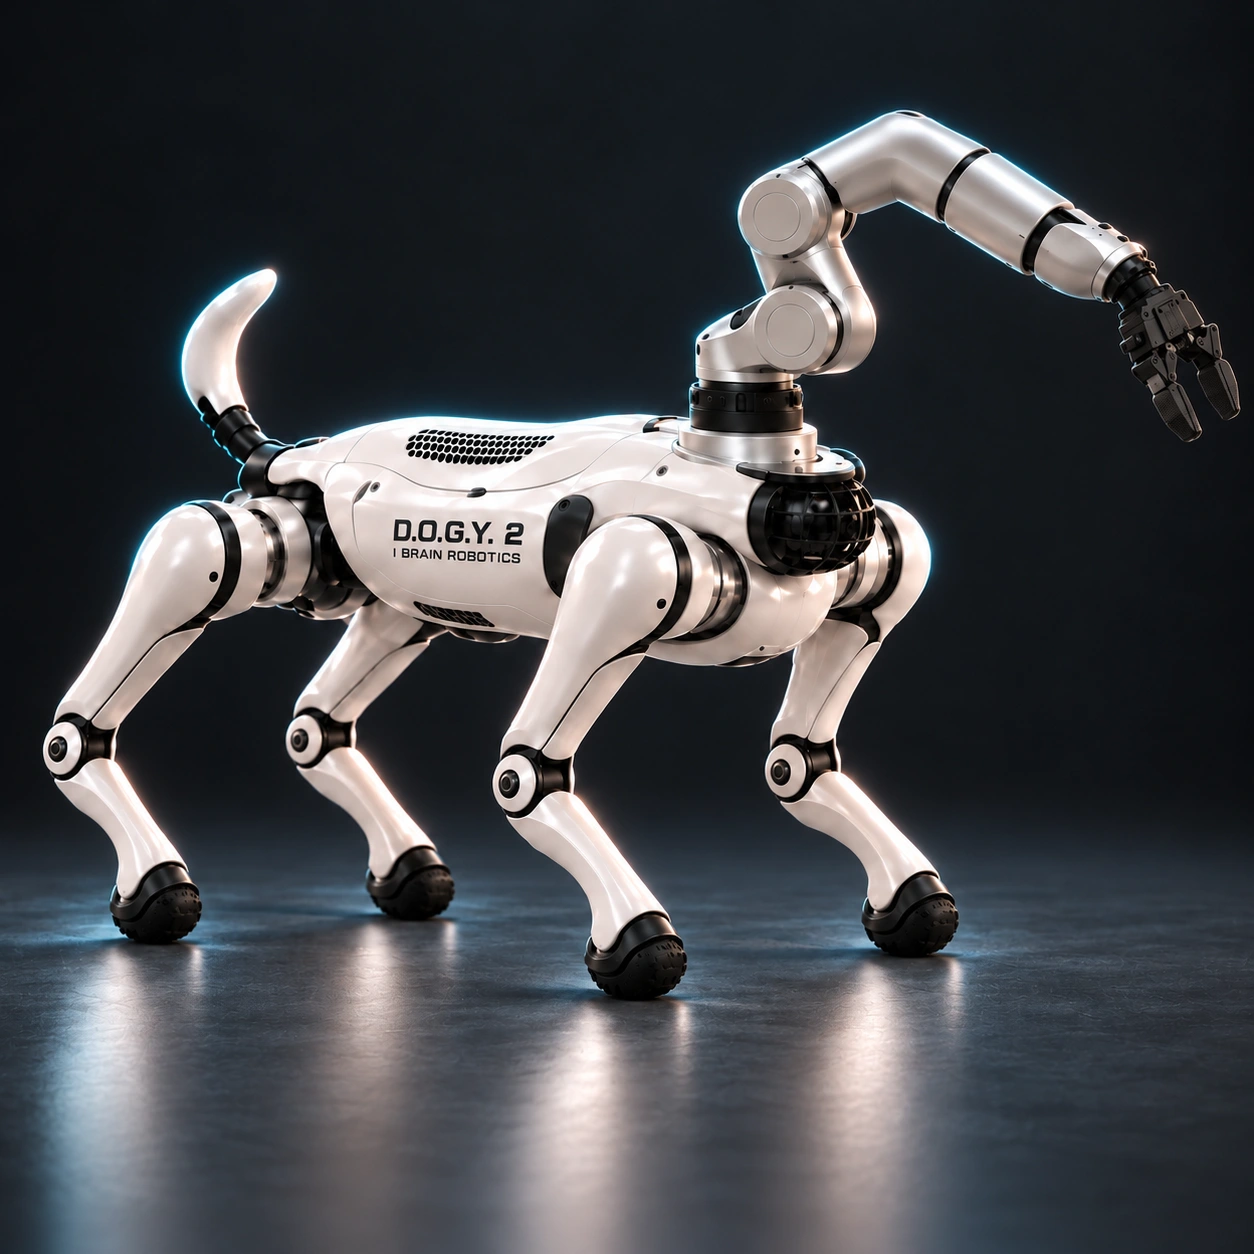
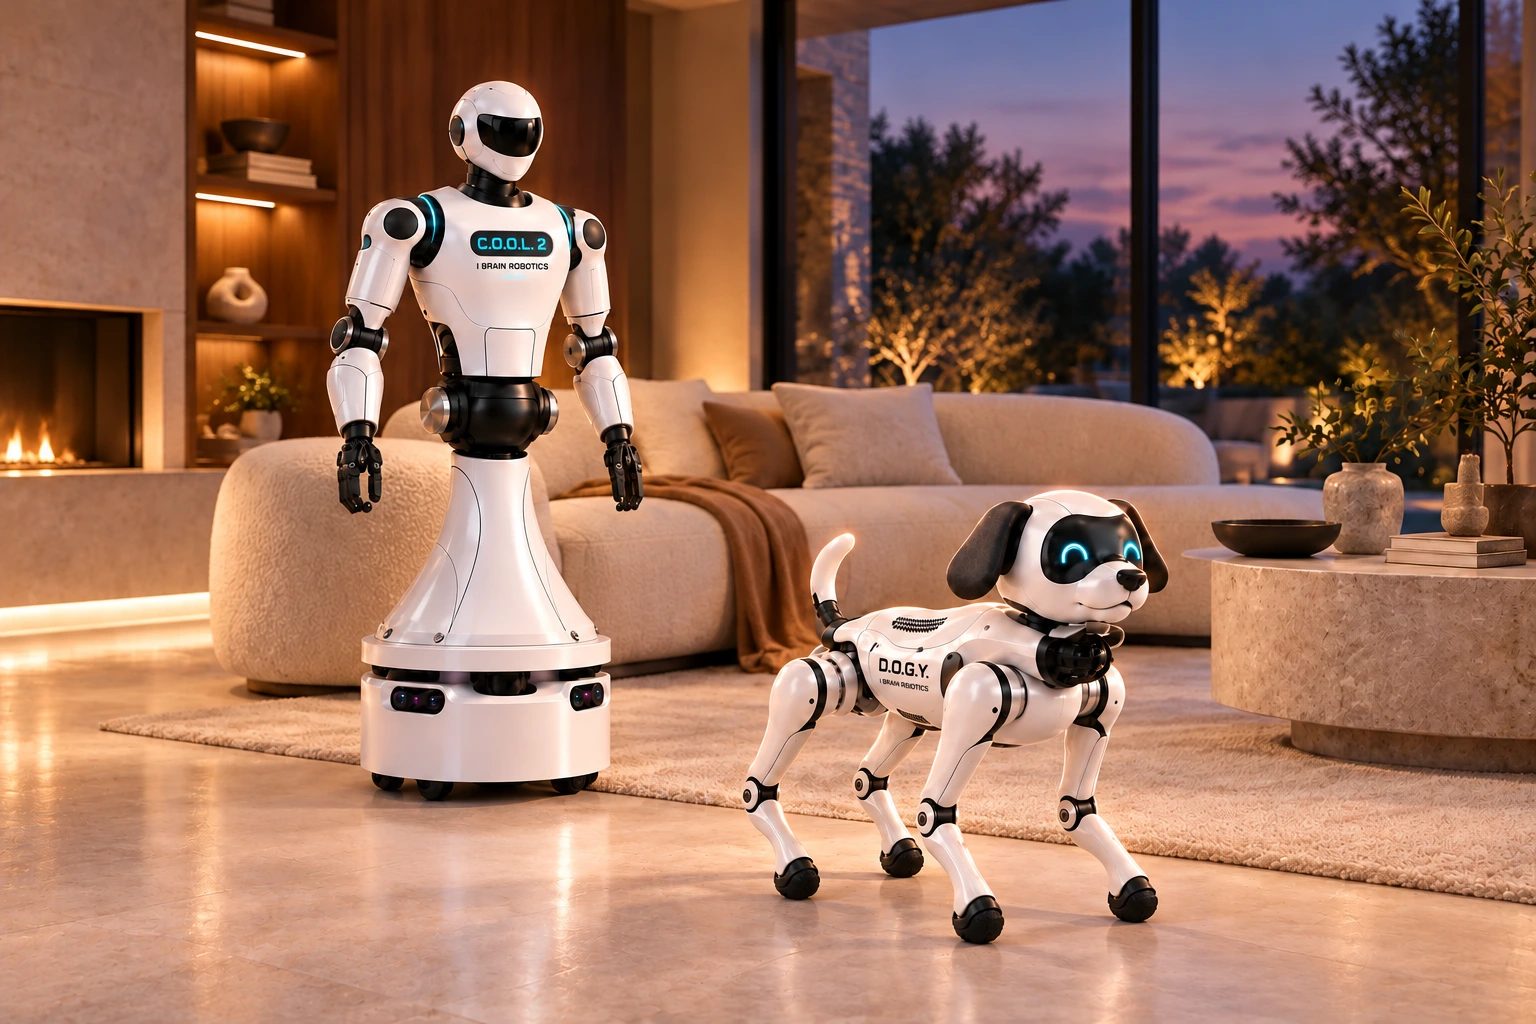
The curved back and belly soften the rectangular platform. The shell creates a canine silhouette while the legs retain the underlying quadruped architecture.
 Book a Demo
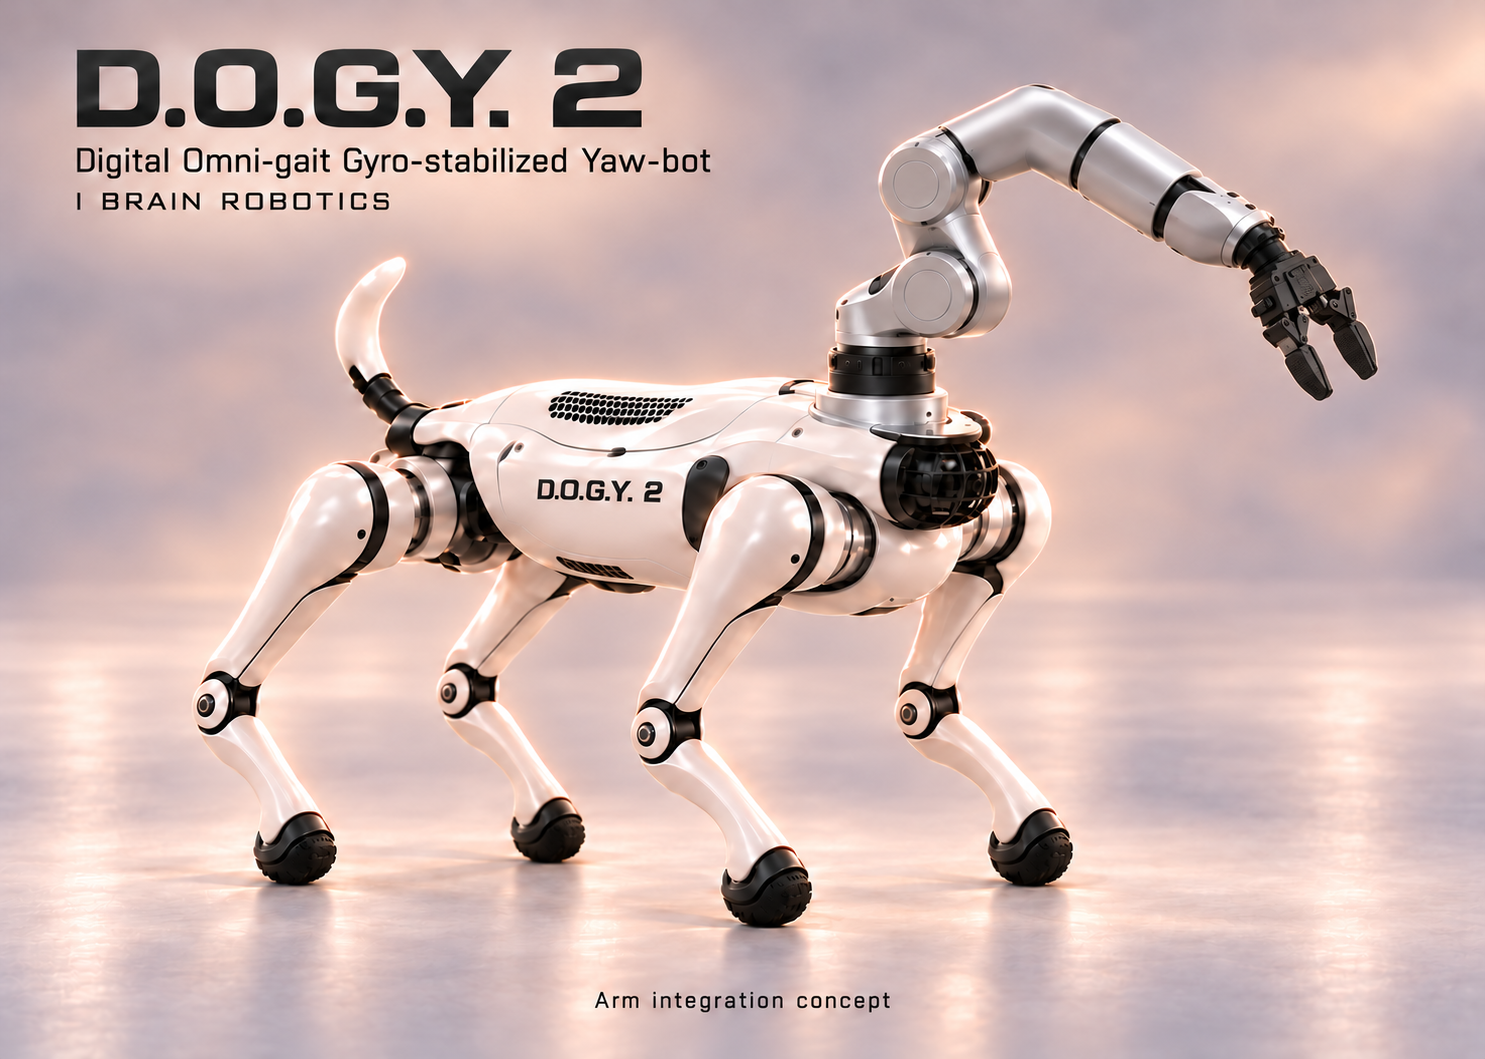
D.O.G.Y.
Digital Omni-gait Gyro-stabilized Yaw-bot
A dog-inspired character built around the Unitree As2 quadruped platform. D.O.G.Y. pairs purposeful four-legged mechanics with a natural curved back, sculpted belly and expressive face.
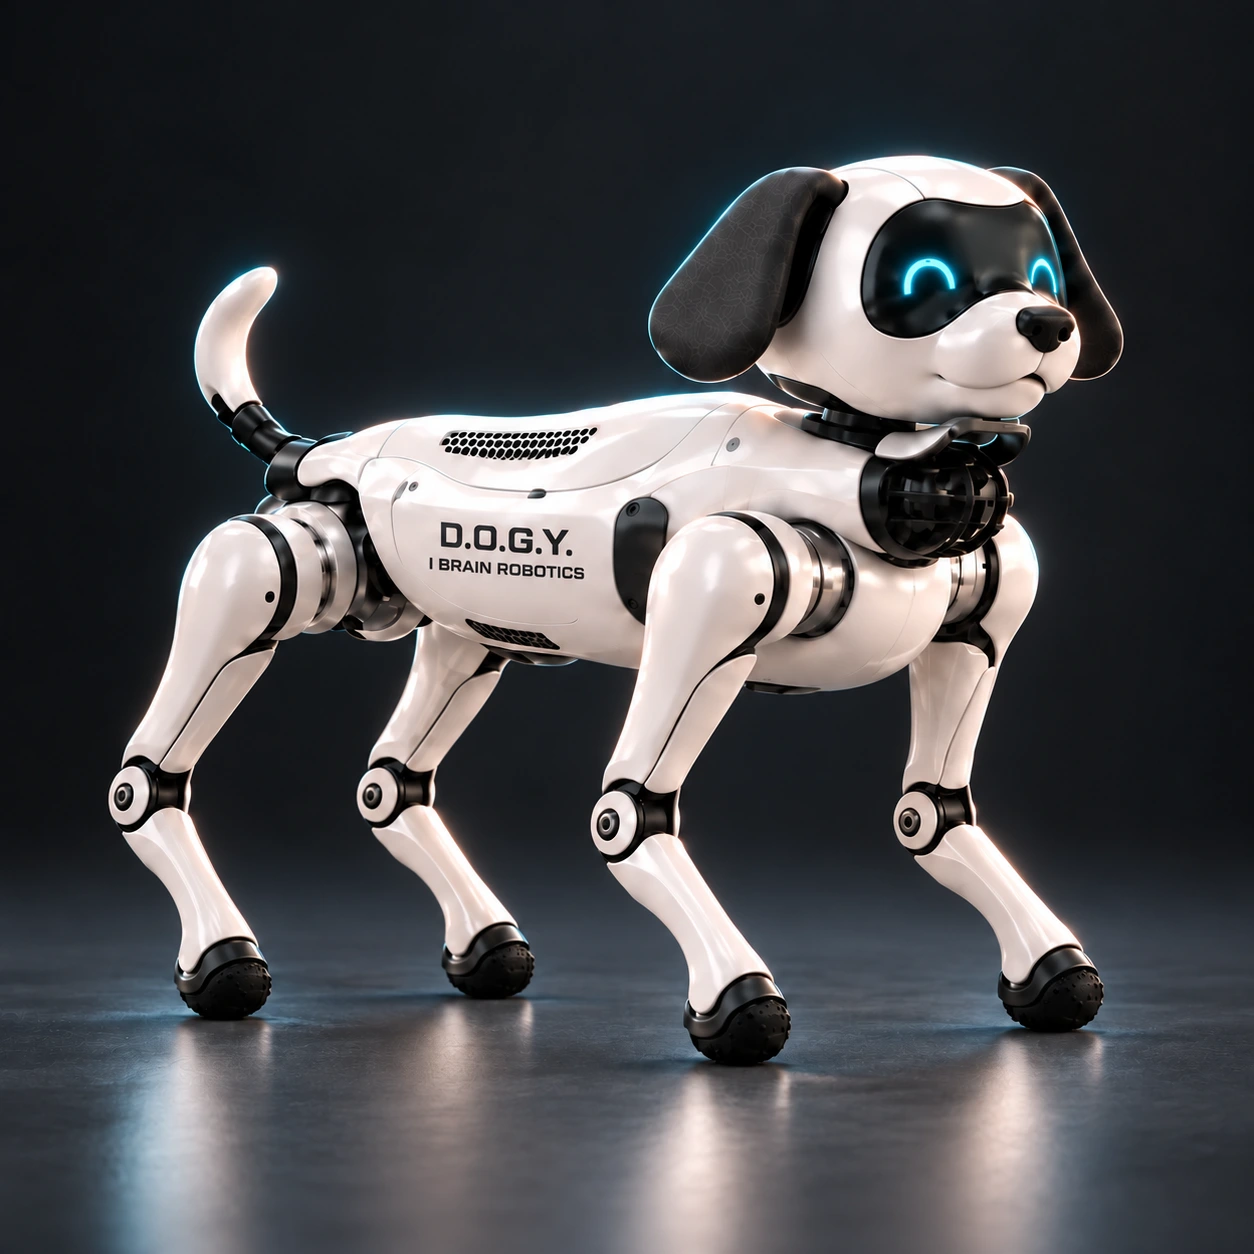 I BRAIN ROBOTICS / D.O.G.Y.
D.O.G.Y. has a character of its own.
Discover what makes it unmistakable.
Hardware foundations and a clear development direction, brought together in one robot.
Four-legged motion on the As2 foundation
Camera and LiDAR configuration
Dog-inspired expressive exterior
Validated navigation and interaction integration
Explore the intended applications.
Help shape a pilot around your space and goals.
A four-legged character for supervised interactions, demonstrations and future home-companion development.
Discuss this applicationA platform direction for exploring quadruped motion, perception and the connection between physical design and control.
Discuss this applicationA recognizable robotic mascot for controlled event spaces, guided visitor experiences and partner demonstrations.
Discuss this applicationApplication concepts describe intended uses. Supported tasks and operating environments will be defined through validation.
The measurements below describe Unitree’s unmodified As2 platform. Editions differ. D.O.G.Y.’s added body, head and electronics can change dimensions, mass, runtime, payload, sensing and weather protection.
| Specification | Detail | Basis |
|---|---|---|
| Base platform | Unitree As2; edition to be finalized | Platform reference |
| Standing dimensions | 720 × 378 × 457 mm / 28.3 × 14.9 × 18.0 in | Unmodified As2 |
| Mass with battery | Approximately 20 kg / 44.1 lb | Unmodified As2 |
| Joint motors | 12 | Unmodified As2 |
| Joint torque | Approximately 65 / 75 / 95 / 95 N·m | AIR / PRO / X / EDU |
| Battery capacity | 8,000 mAh AIR; 15,000 mAh PRO / X / EDU | Edition-dependent |
| Unloaded walking runtime | Approximately 2 h AIR; 4 h PRO / X / EDU | Manufacturer laboratory figures |
| Continuous walking load | 10 / 13 / 15 / 15 kg | AIR / PRO / X / EDU |
| LiDAR | Unitree L2 AIR; industrial 64–128-line on other editions | Edition-dependent |
| Connectivity | Wi-Fi 6 and Bluetooth 5.2 | Unmodified As2 |
| Development interfaces | Secondary development supported on X / EDU | Edition-dependent |
| Final D.O.G.Y. performance | To be validated after body and head integration | Validation pending |
No. They describe the starting platform. Added components affect the complete robot, so final D.O.G.Y. dimensions, endurance, carrying capacity and operating limits must be measured after integration.
The design must preserve the selected platform’s sensing. The exact head mounting and sensor clearance are engineering requirements, not something the appearance render alone can establish.
The finished product’s environmental rating and supervision guidance have not been released. Ratings for an unmodified As2 do not automatically transfer to D.O.G.Y.’s custom exterior.
Follow its development or tell us about the experience you want to create.
No payment or reservation required.