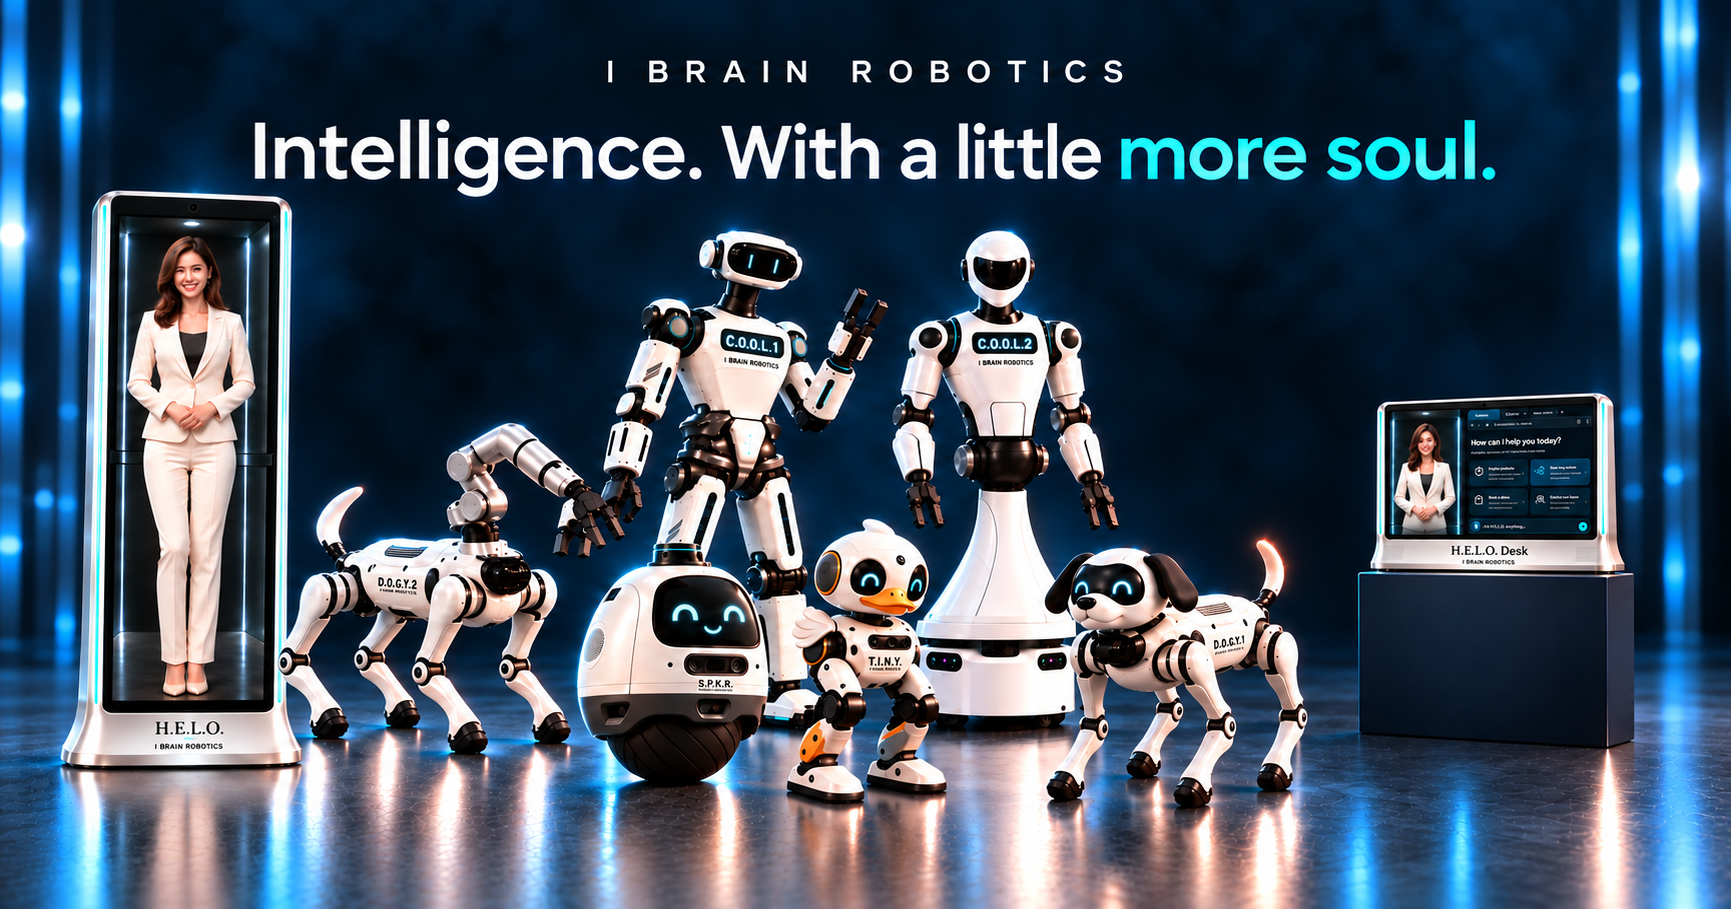
One continuous silhouette
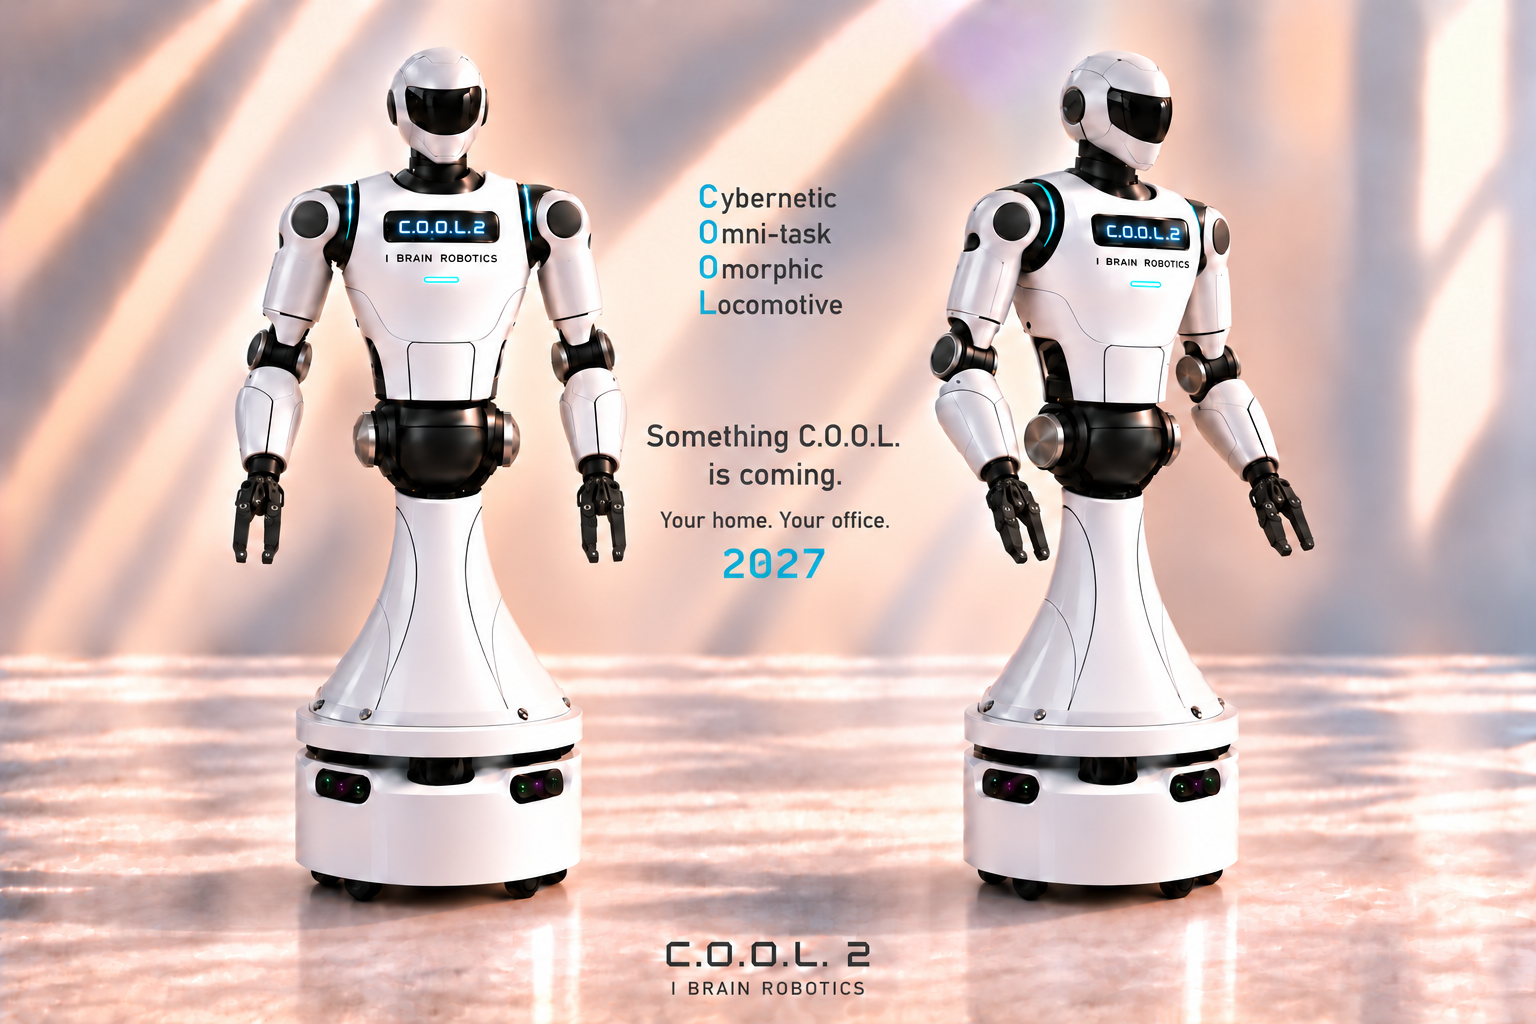
A curved outer fairing visually connects the upper body to the chassis. The design follows available mounting locations instead of treating the lower body as an unrelated platform.
 Book a Demo
C.O.O.L. 2
Cybernetic Omni-task Omorphic Locomotive
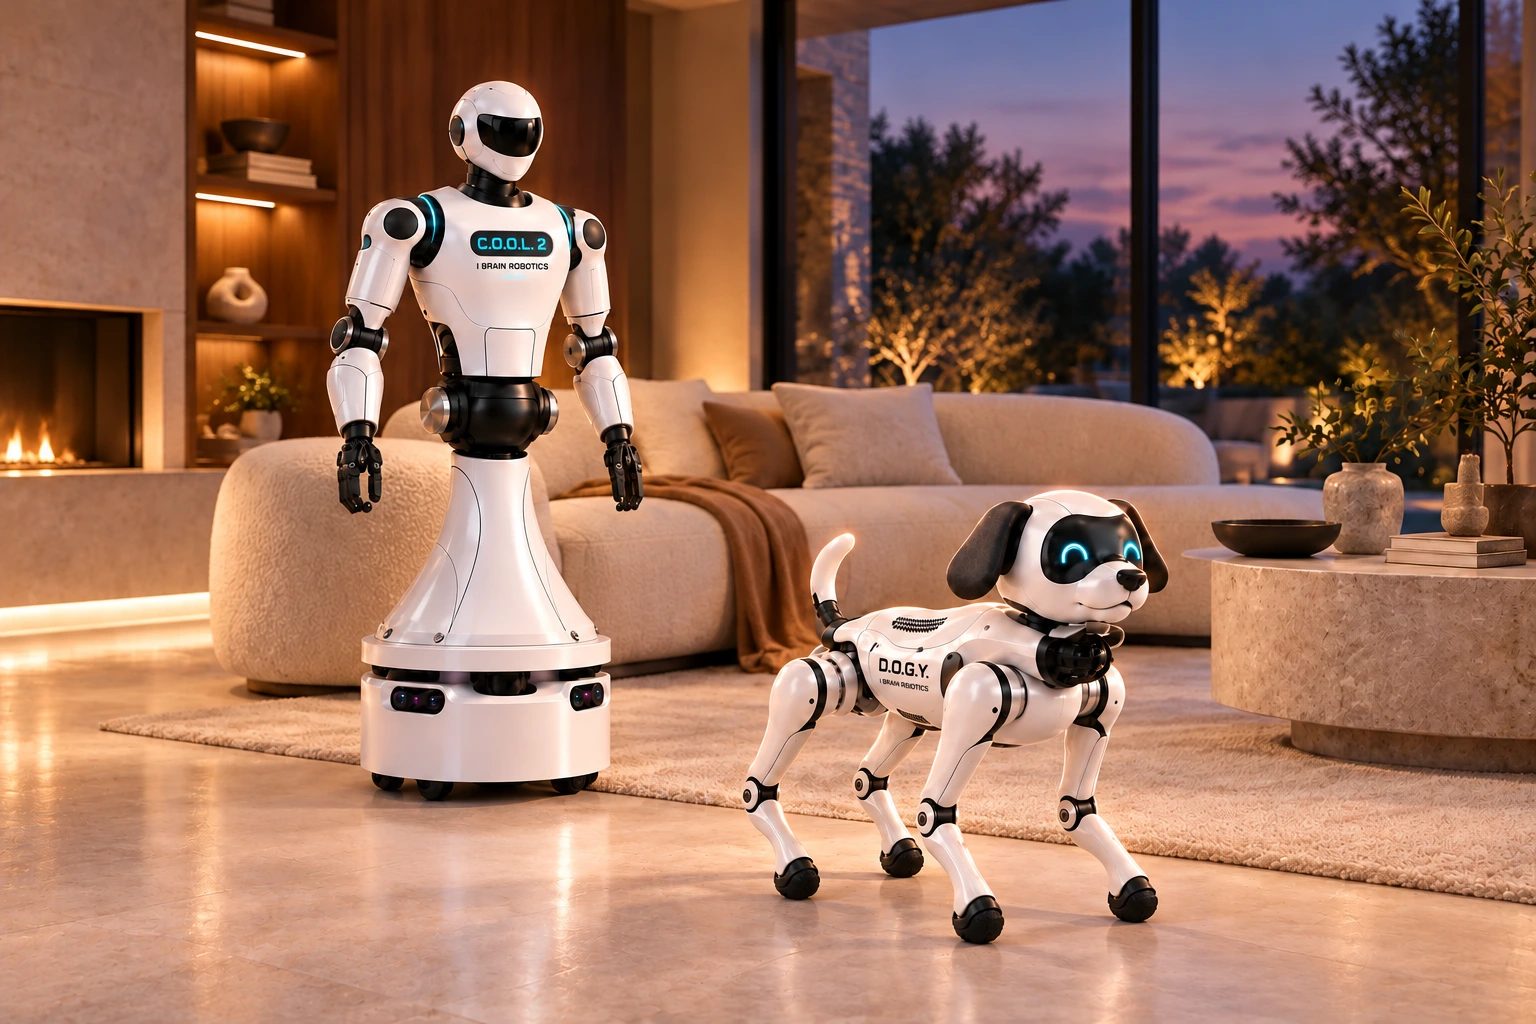
A humanoid upper body on a compact mobile base. C.O.O.L. 2 is shaped around indoor interaction: a familiar face, articulated arms and a sculpted body that flows into its wheeled chassis.
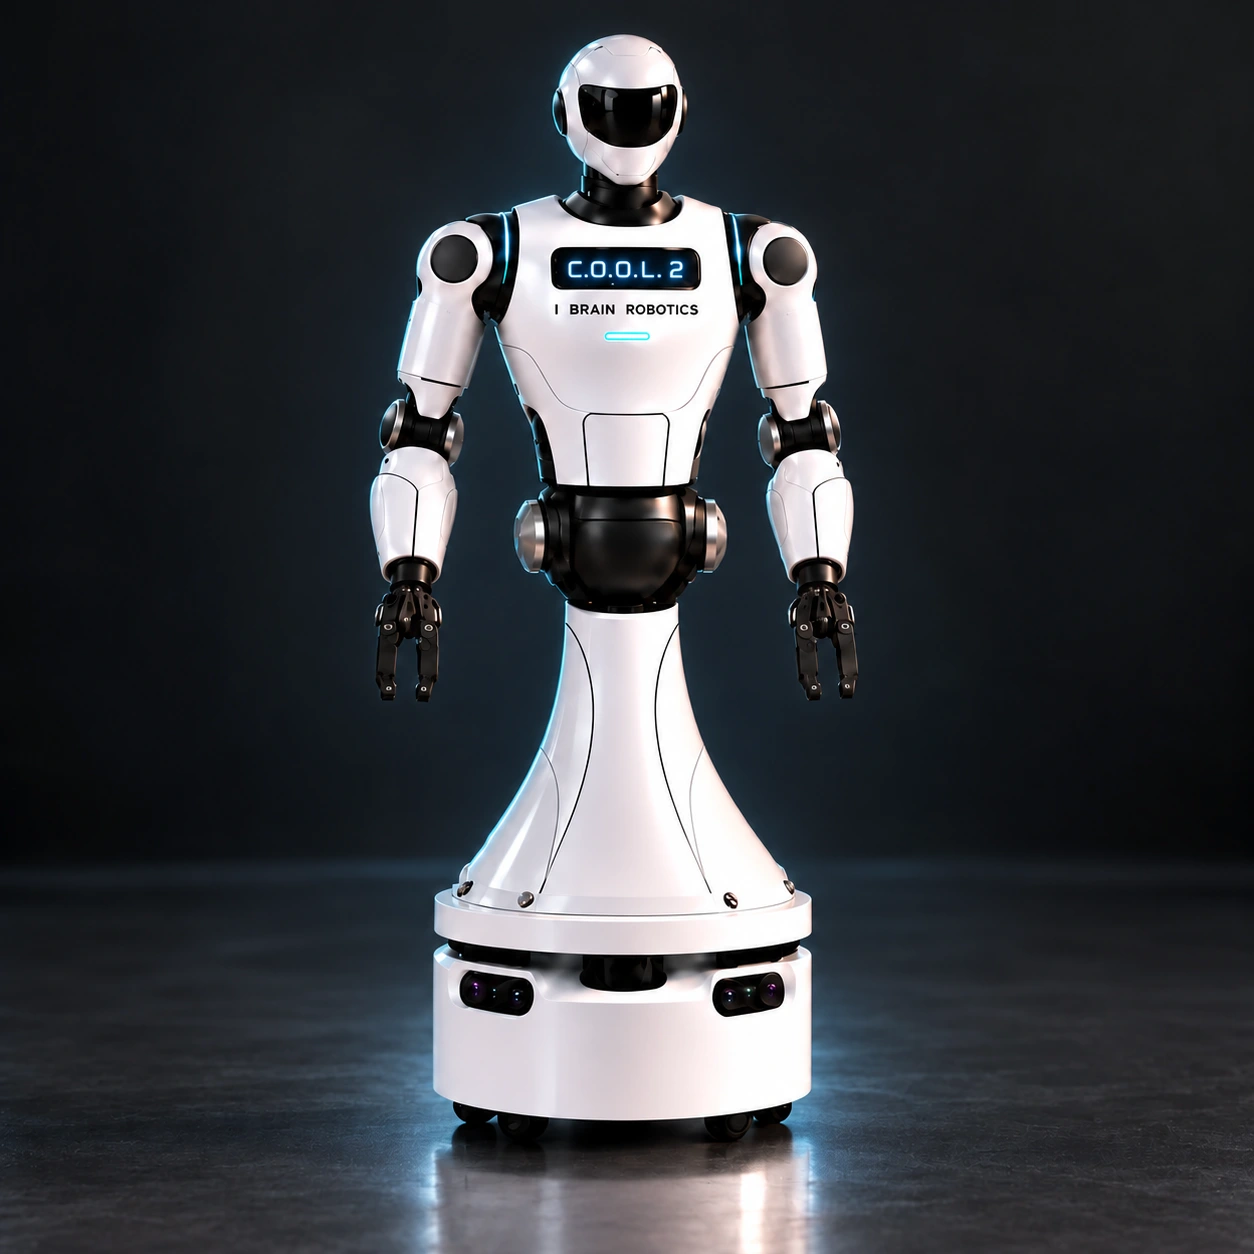 I BRAIN ROBOTICS / C.O.O.L. 2
C.O.O.L. 2 has a character of its own.
Discover what makes it unmistakable.
Hardware foundations and a clear development direction, brought together in one robot.
Wheeled movement for indoor spaces
Humanoid face, torso and articulated arms
Autonomous indoor navigation integration
Defined object-handling workflows
Explore the intended applications.
Help shape a pilot around your space and goals.
A pilot concept for greeting visitors, presenting information and creating a distinctive first impression in prepared indoor spaces.
Discuss this applicationExplore guided introductions, conversational experiences and future room-to-room workflows on accessible floors.
Discuss this applicationA wheeled approach to social presence and future assistance, with household tasks defined through real-world validation.
Discuss this applicationApplication concepts describe intended uses. Supported tasks and operating environments will be defined through validation.
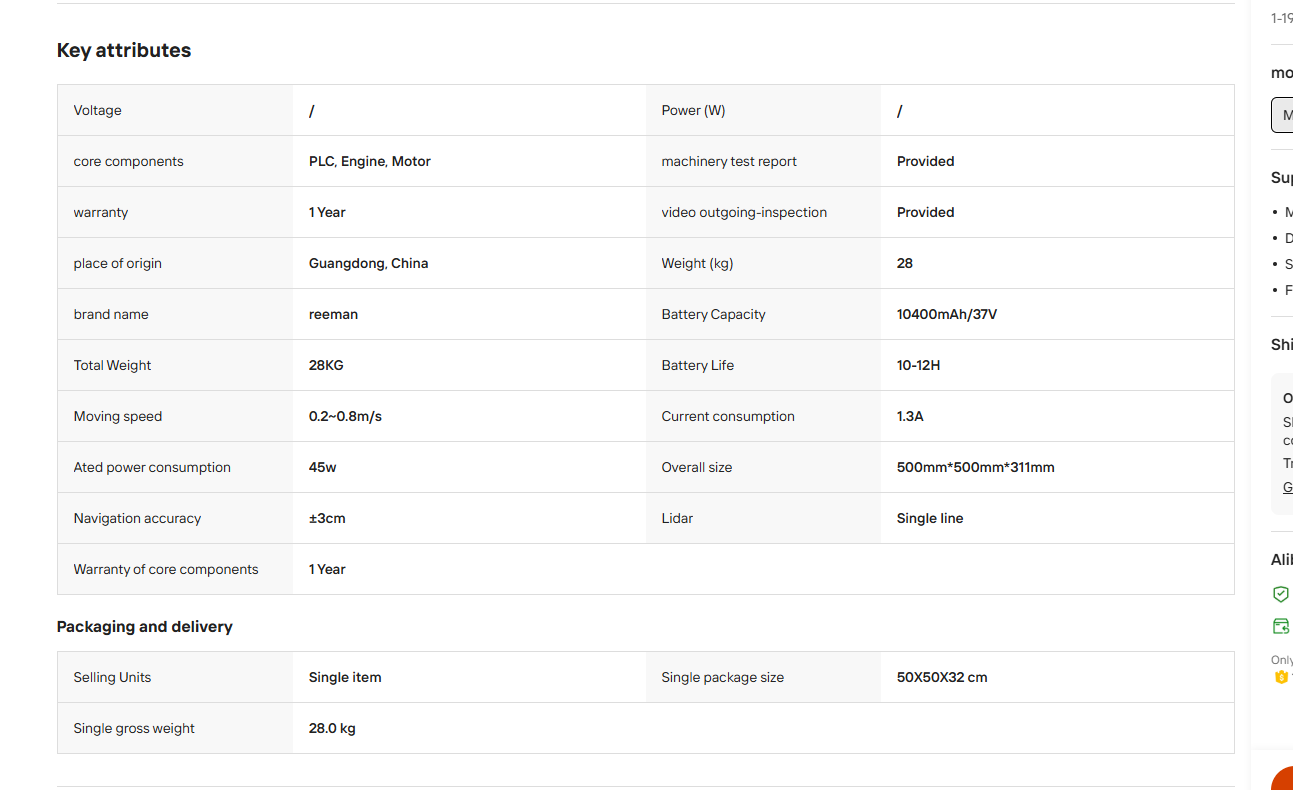
The design combines the established humanoid upper body with a Reeman mobile-base reference. Numerical chassis figures below come from the selected supplier specification image. They exclude the torso, arms, head, covers and added electronics; final system performance requires validation.
| Specification | Detail | Basis |
|---|---|---|
| Locomotion | Compact Reeman wheeled mobile base | Selected supplier reference |
| Reference chassis dimensions | 500 × 500 × 311 mm / 19.7 × 19.7 × 12.2 in | Supplier listing; chassis only |
| Reference chassis weight | 28 kg / 61.7 lb | Supplier listing; chassis only |
| Listed speed range | 0.2–0.8 m/s / 0.45–1.8 mph | Supplier listing; chassis only |
| Reference battery | 10,400 mAh / 37 V | Supplier listing; chassis only |
| Listed battery life | 10–12 hours; load and test conditions unspecified | Supplier claim; not system runtime |
| Rated power consumption | 45 W | Supplier listing; chassis only |
| Listed navigation accuracy | ±3 cm; test conditions unspecified | Supplier listing; chassis only |
| Chassis LiDAR | Single-line LiDAR | Selected supplier reference |
| Upper body | Humanoid torso with two articulated arms | Design architecture |
| Head | Existing articulated head architecture retained | Design architecture |
| End effectors | Compact grippers shown | Design direction |
| Body transition | Sculpted fairing between torso and chassis | Design direction |
| Perception layout | Front-facing base sensor apertures preserved | Design direction |
| Intended surfaces | Prepared, accessible indoor floors | Development scope |
| Navigation | Mapping, obstacle awareness and route planning integration | In development |
| Interaction | Voice and visual interaction experience | Planned |
| Dimensions & weight | To be measured on the final selected assembly | Validation pending |
| Arm reach & payload | Supplier configuration and testing required | Validation pending |
| Runtime & charging | Battery and charging configuration to be published | Validation pending |
| Availability | 2027 target; pricing not announced | Program target |
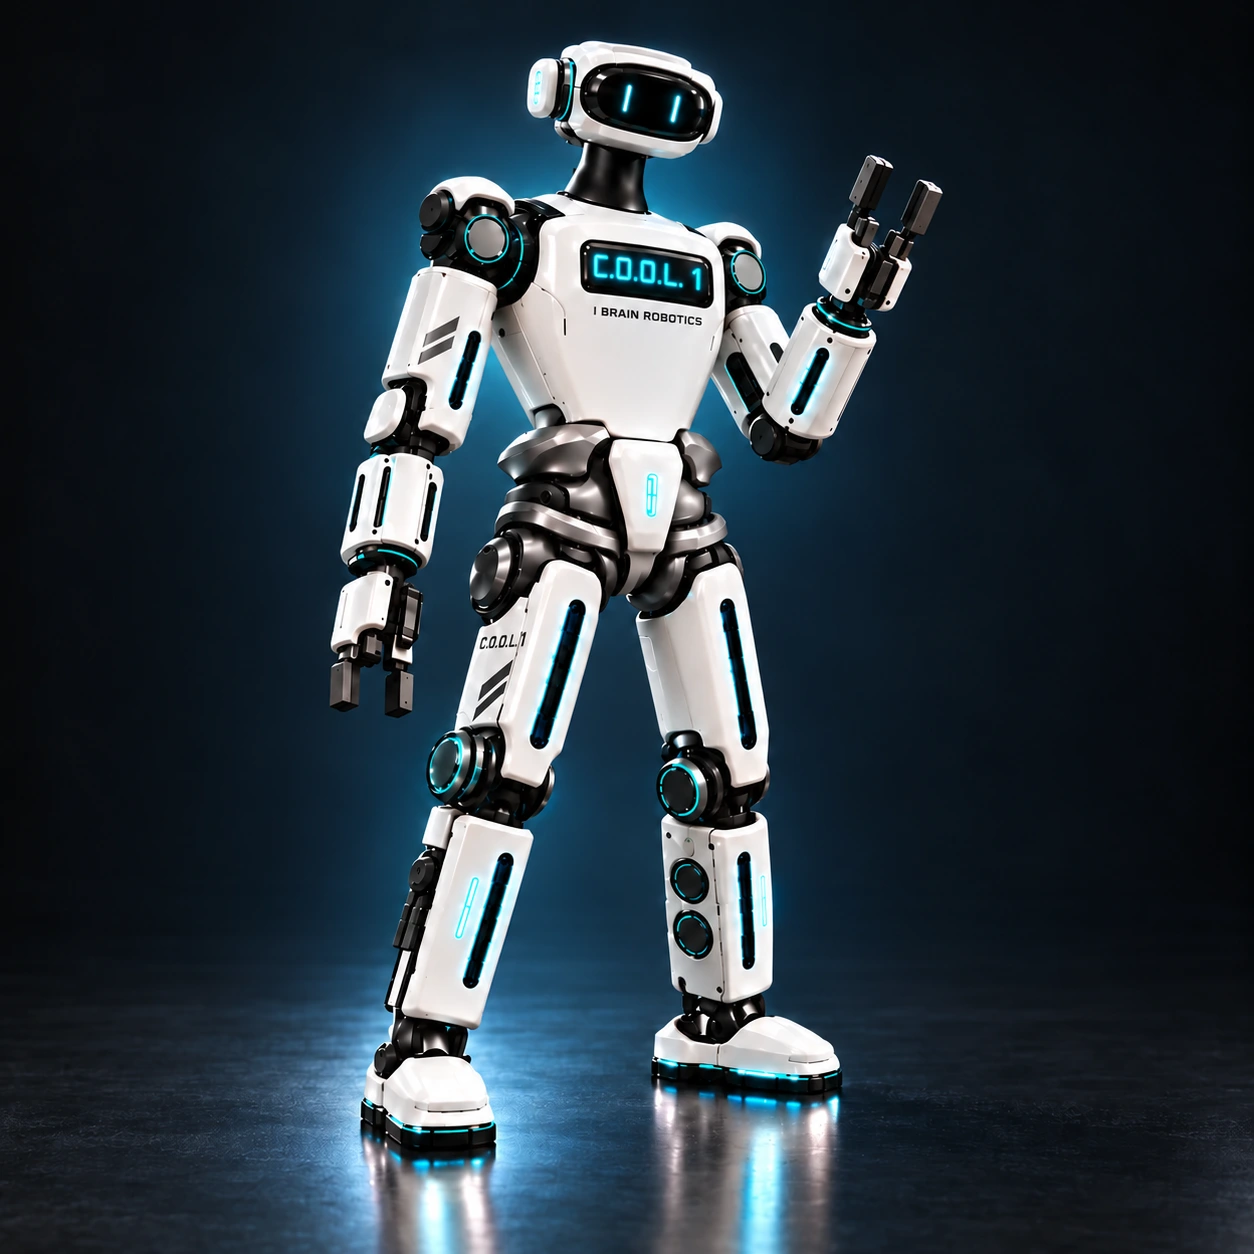
C.O.O.L. 1 uses two legs. C.O.O.L. 2 uses a wheeled mobile base beneath a humanoid upper body, making indoor floor access a central part of its intended use. They are different form factors, not a simple good–better ranking.
Stair climbing is not part of the published C.O.O.L. 2 design. Deployment planning should assume accessible floors and appropriate transitions until tested limits are released.
Autonomous navigation is a development objective. Obstacle detection, stopping behavior, operating speed and the permitted environment must be validated together before unattended use is offered.
Follow its development or tell us about the experience you want to create.
No payment or reservation required.